Variable-Baseline Depth Sensing
What happens to depth estimation when the cameras are very far apart?
 Eddie OffermannHardware prototyping, enclosure, lens calibration, disparity-mapping algorithm, demonstration and report
- Role
- Hardware prototyping, enclosure, lens calibration, disparity-mapping algorithm, demonstration and report
- Areas
- Computer Vision, Hardware, Research, Optics
Most commercial depth sensors use some form of disparity mapping. They compare two viewpoints, either two cameras or a pattern emitter and a camera, usually a few millimeters or centimeters apart.
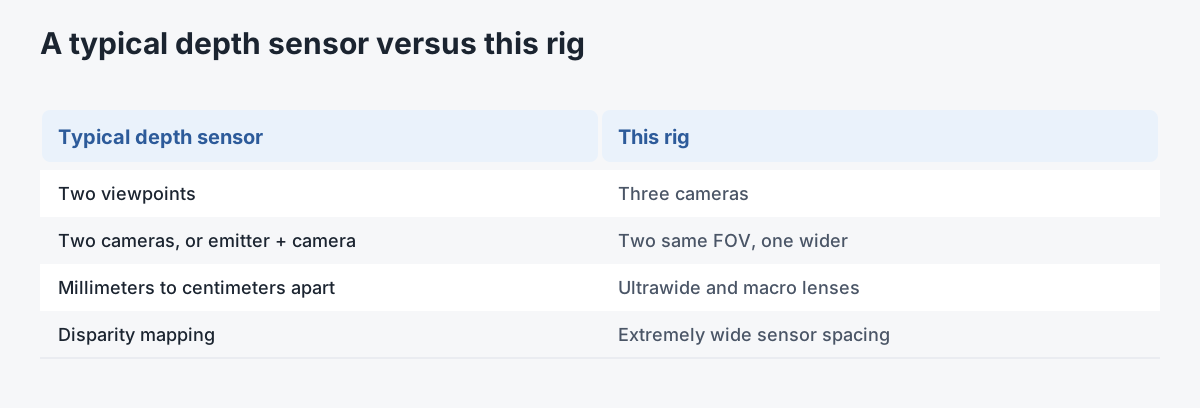
This exploration measured what changes outside that comfort zone:
- Three cameras: two with the same field of view and one wider.
- Ultrawide and macro lenses.
- Above all, extremely wide spacing between the sensors.
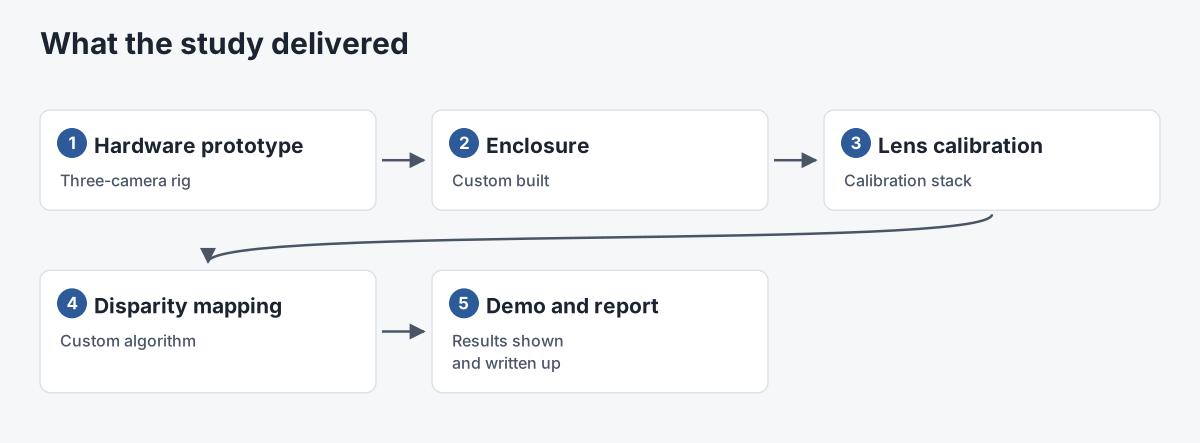
We built the hardware and enclosure, the lens calibration stack and a custom disparity-mapping algorithm, and delivered a demonstration and a report.
Part of Enhanced Presence.
Related work
-
Computational Optics
Hyperspectral images from the ordinary camera in a phone.
-

HoloFlect
A modular, upgradeable AR headset platform built for enterprise.
-
ISO-5 Optical Cleanroom
A cleanroom lab built to turn phone cameras into spectral instruments.
-
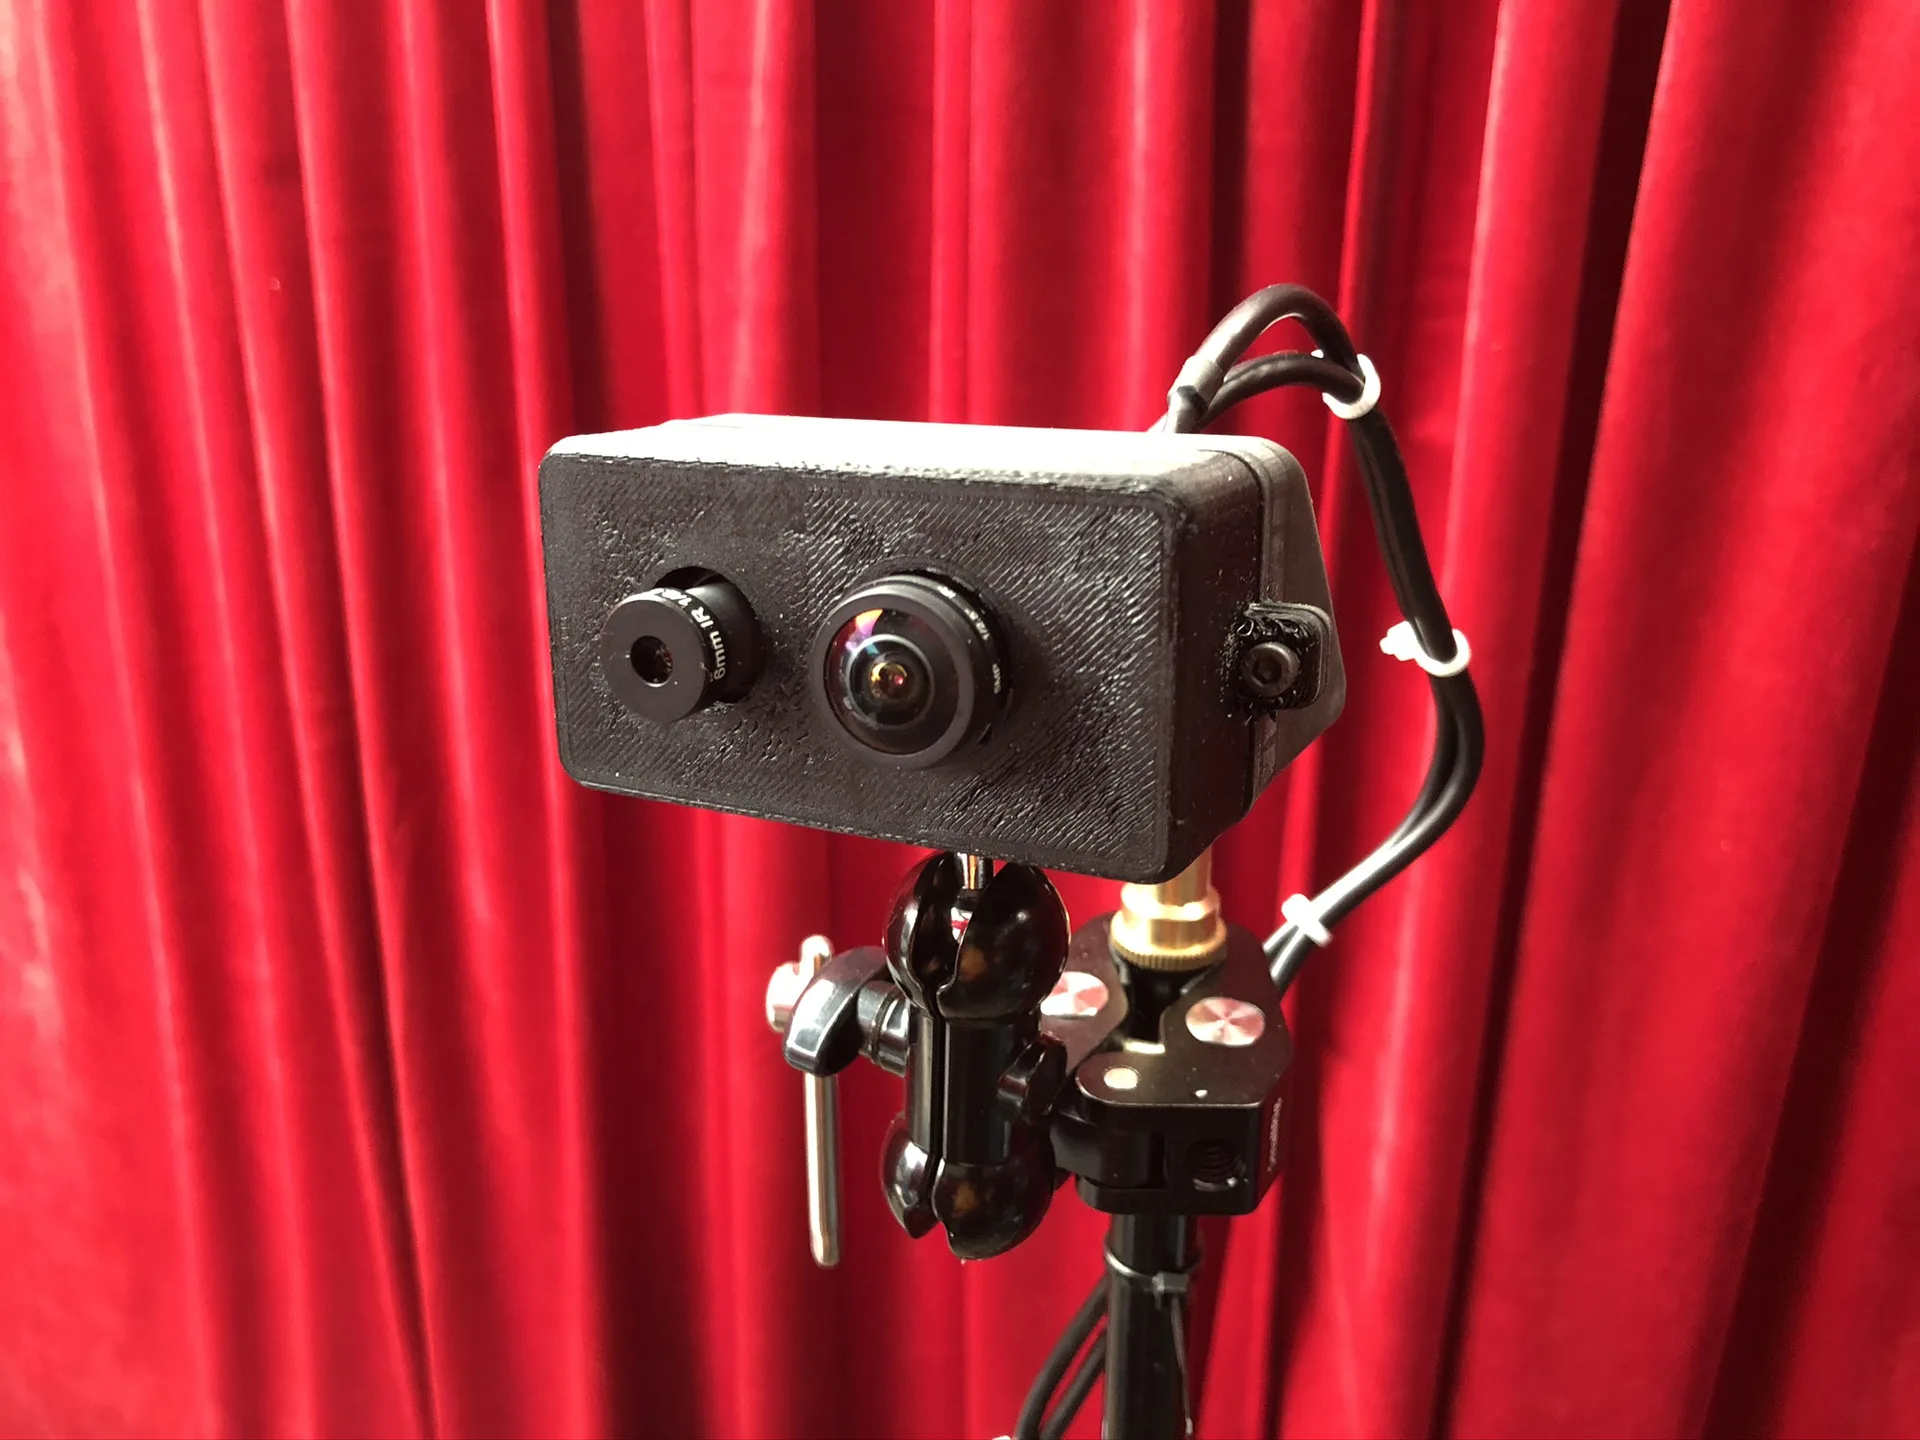
Mixed-FOV Depth Sensing
Pairing an ultrawide depth sensor with a narrow one for detail where it matters.