Volumetric Streaming over RTC
Realtime 3D capture of a person, merged from two sensors and streamed over the internet.
 Eddie OffermannHardware selection and rig build, software architecture, engineering, demonstration
- Role
- Hardware selection and rig build, software architecture, engineering, demonstration
- Areas
- Telepresence, Hardware, Computer Vision

This exploration focused on realtime volumetric capture and streaming over the internet.
We selected the sensors, then designed, built and calibrated the test rig: two Intel RealSense D435 cameras on 3D-printed mounts and an 80/20 frame, positioned so each fills in what the other can't see. We built two spacings. The narrow rig sits on a monitor and fills occlusions tightly for laptop-sized screens. The wide rig spreads the sensors along a longer rail and fills much more, but only suits television-sized displays.
We wrote the software that merges the two volumes, correcting for alignment and color, and encoded the result in a format that can be streamed between remote devices and rebuilt on the far end over current network infrastructure.
It became the foundation for the rest of Enhanced Presence.
Gallery
The first realtime stream: two sensors merged into one volume. The same stream from another angle. 
The wide rig on a stand, with the sensors far apart to fill more occlusions. 
Assembling the rig. 
The cameras and their printed mounting plates. 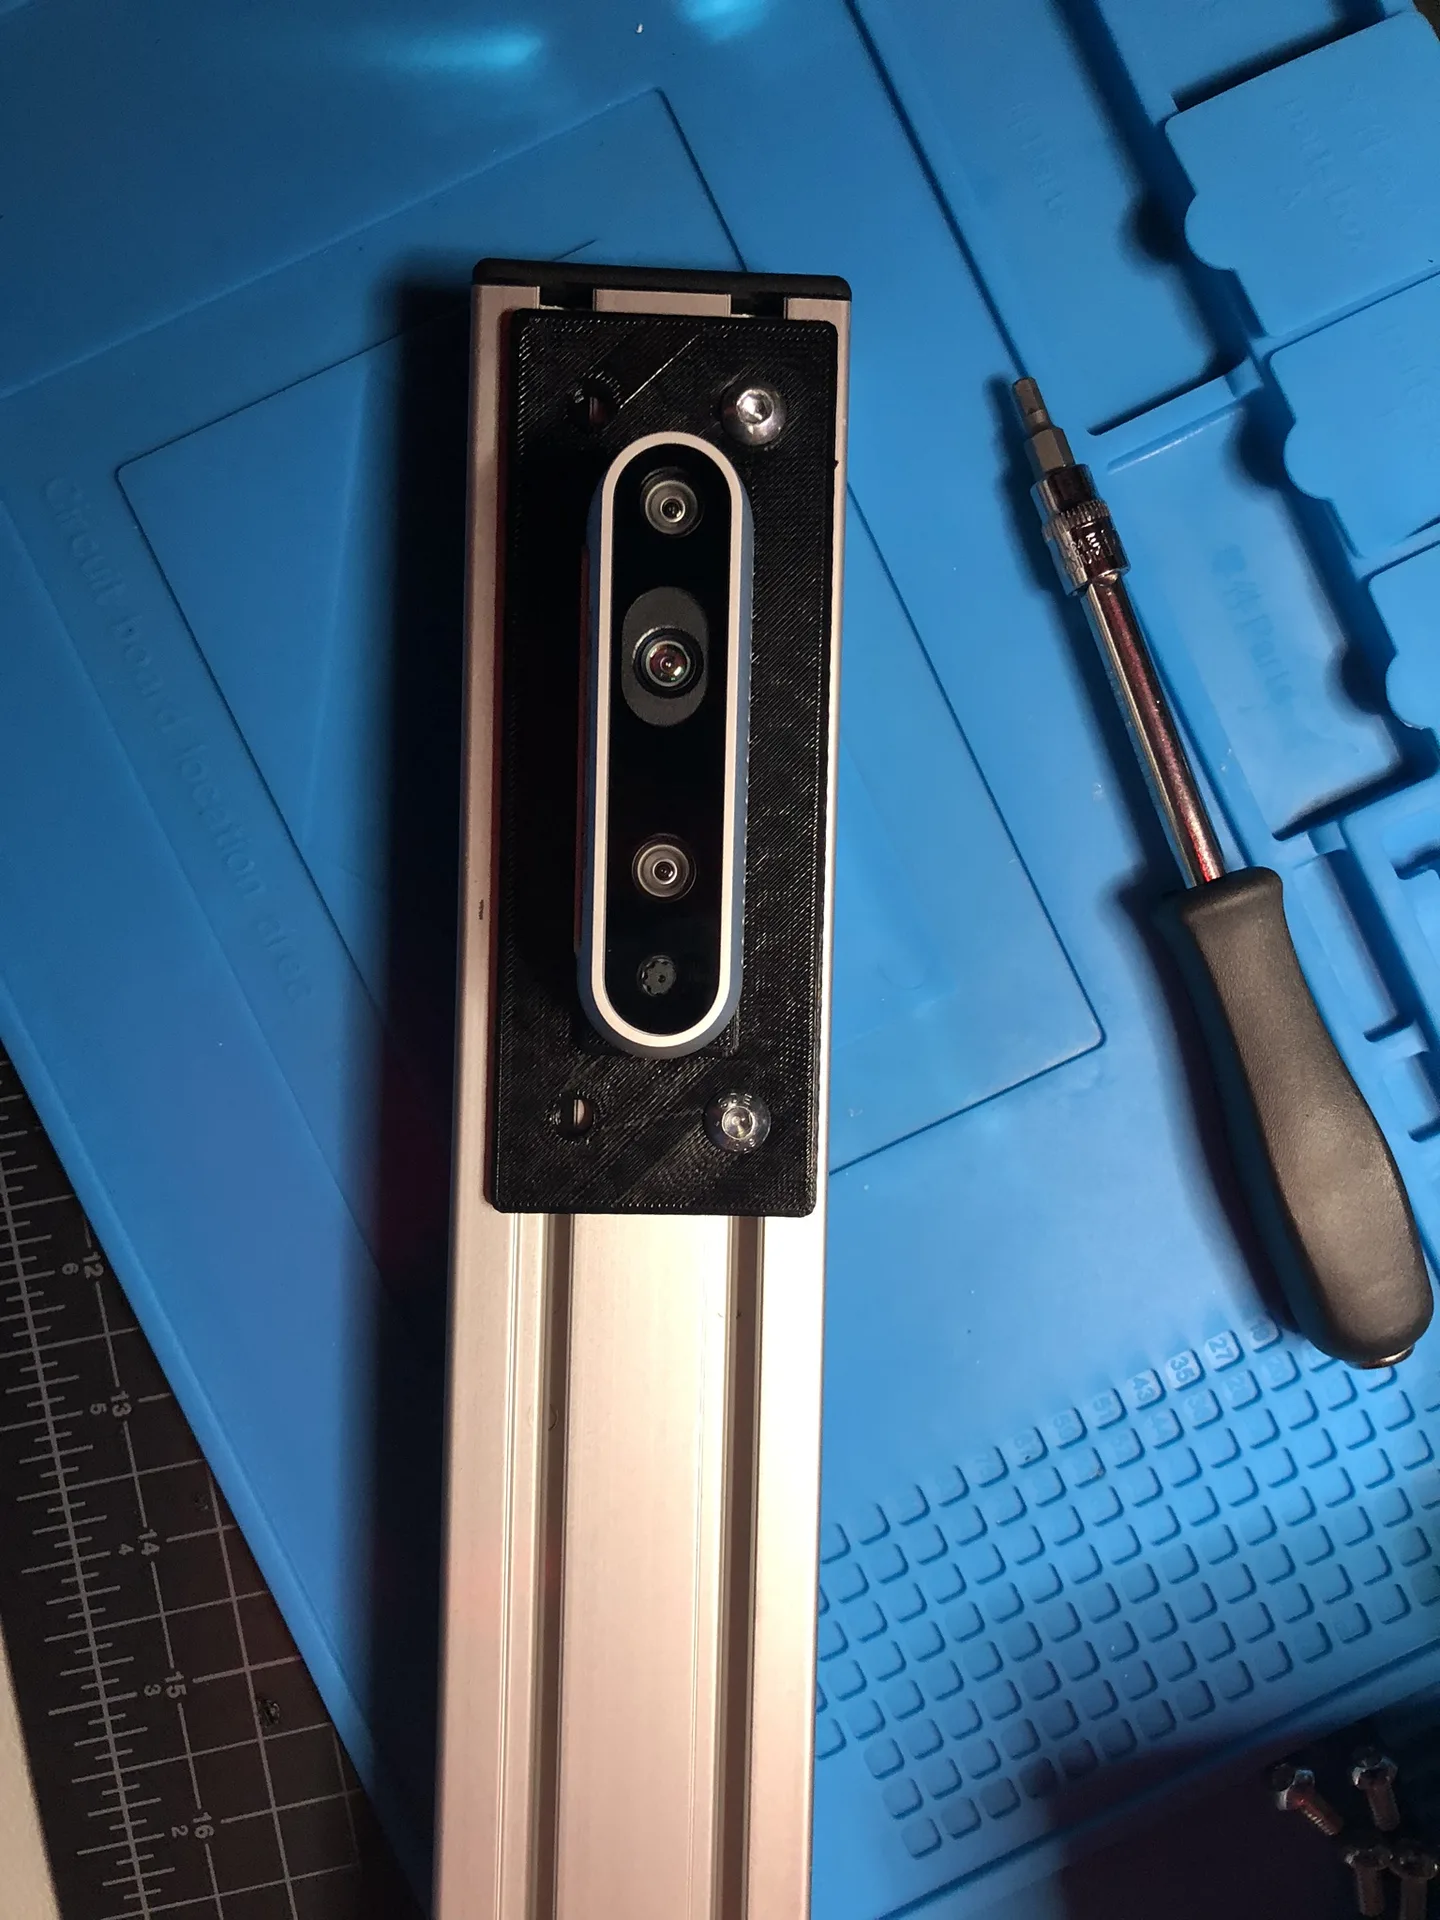
Each sensor bolts to the 80/20 rail through a printed plate. 
A printed plate, sized to the sensor. 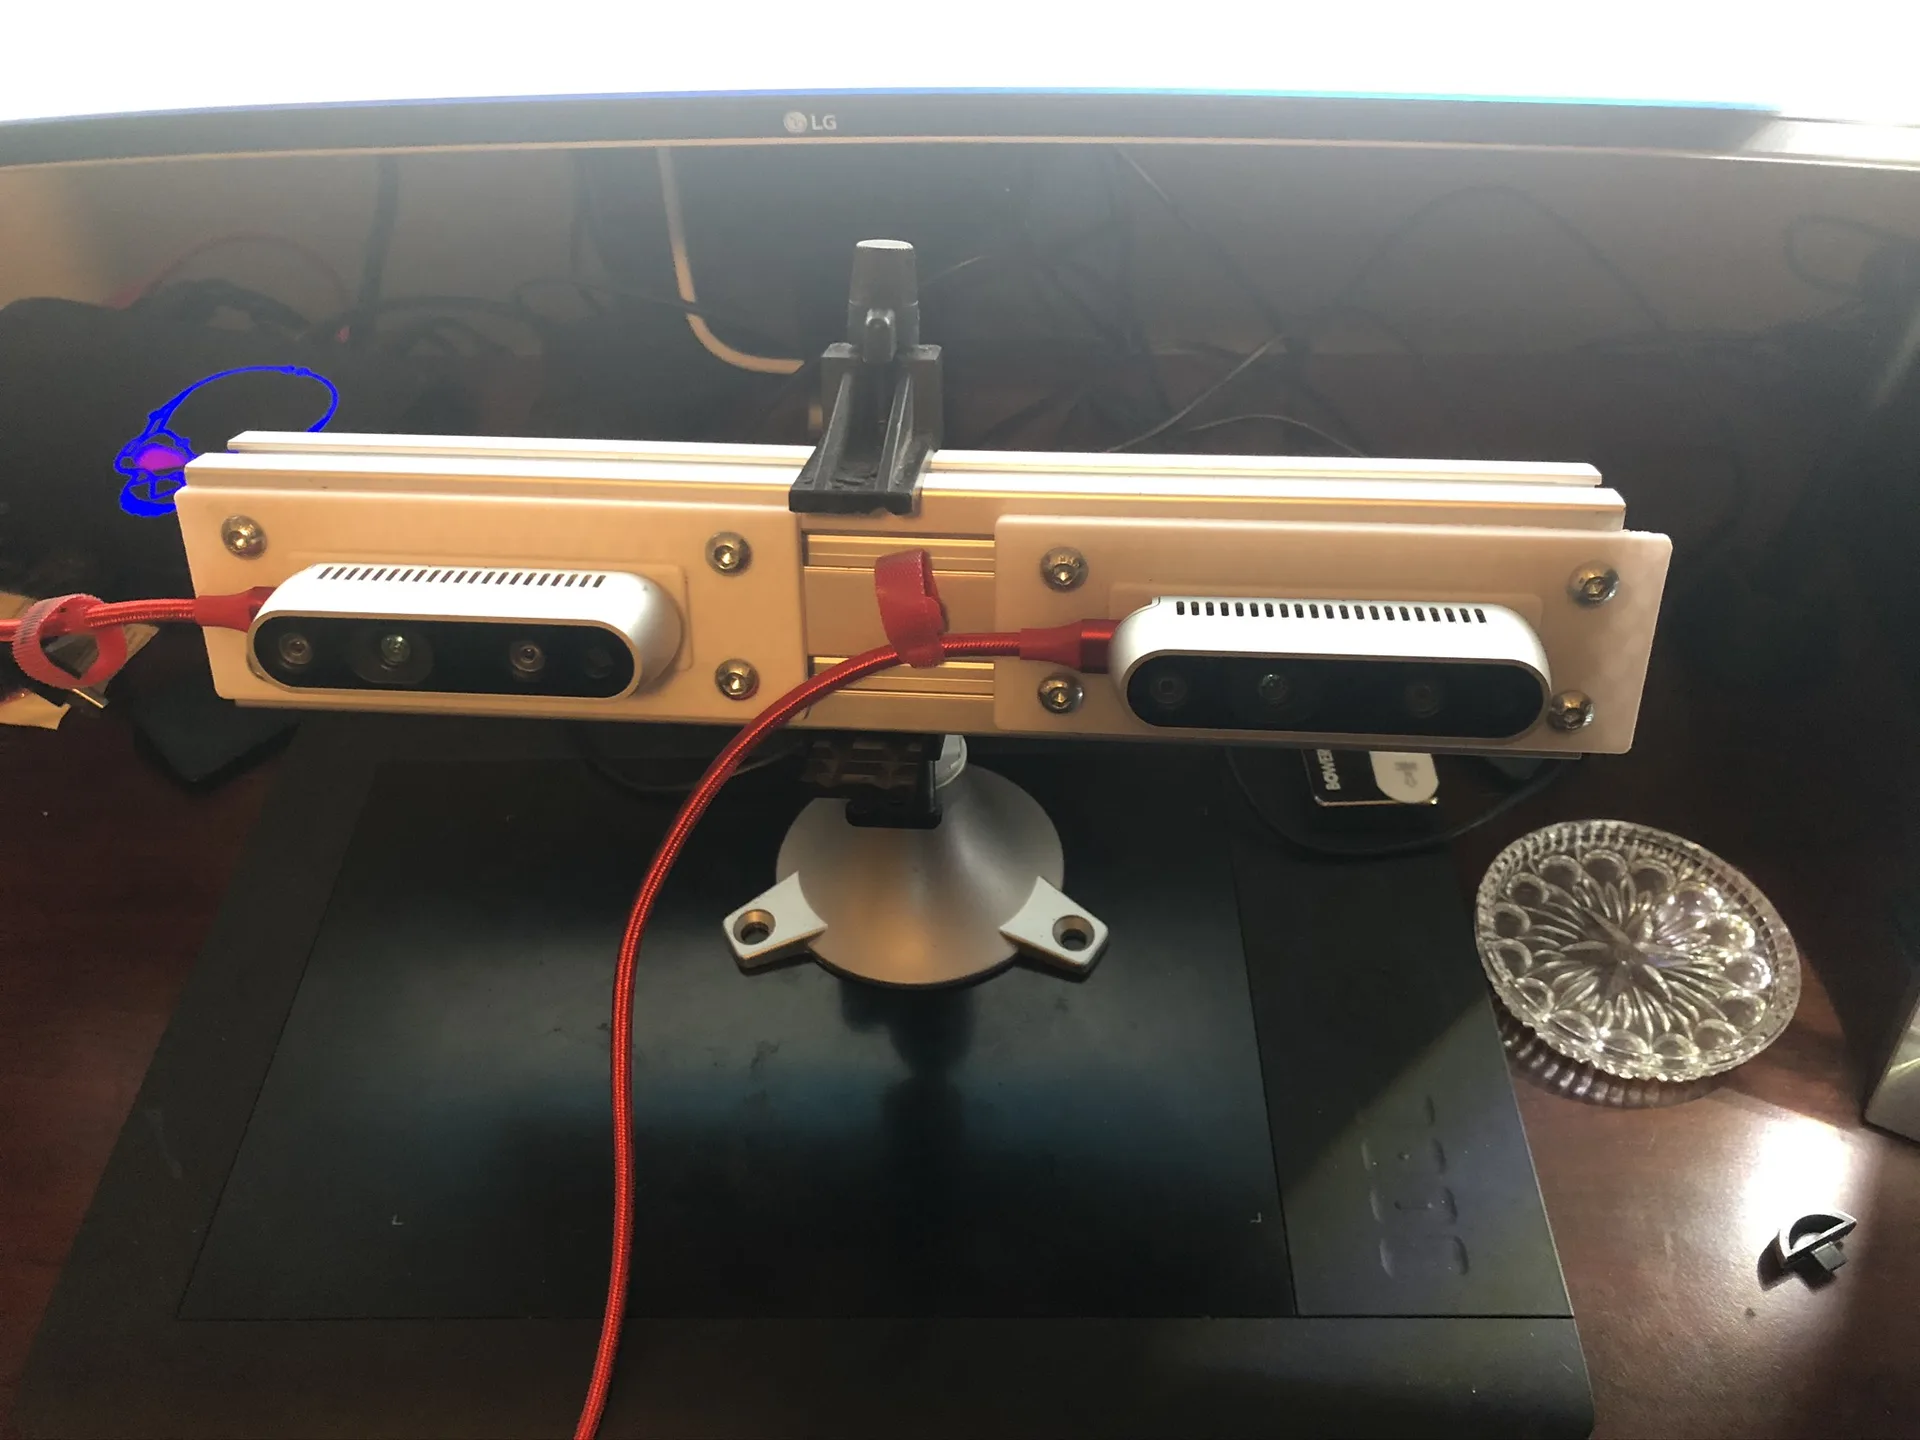
The narrow rig, sized for laptop and desktop screens.
Related work
-

Enhanced Presence
A run of prototypes chasing the feeling of being in the room with someone far away.
-
Glasses-Free 3D Telepresence
Volumetric calls on a 45-inch autostereoscopic display, no glasses required.
-
North Star Stereoscopic Telepresence
A preview of a fully 3D, ultra-HD video call with realtime perspective shift.
-

Projection AR Tabletop Gaming
Augmented reality projected onto an ordinary table, with touch.